
Dynamics of a Predator-Prey Model with Numerical Integration

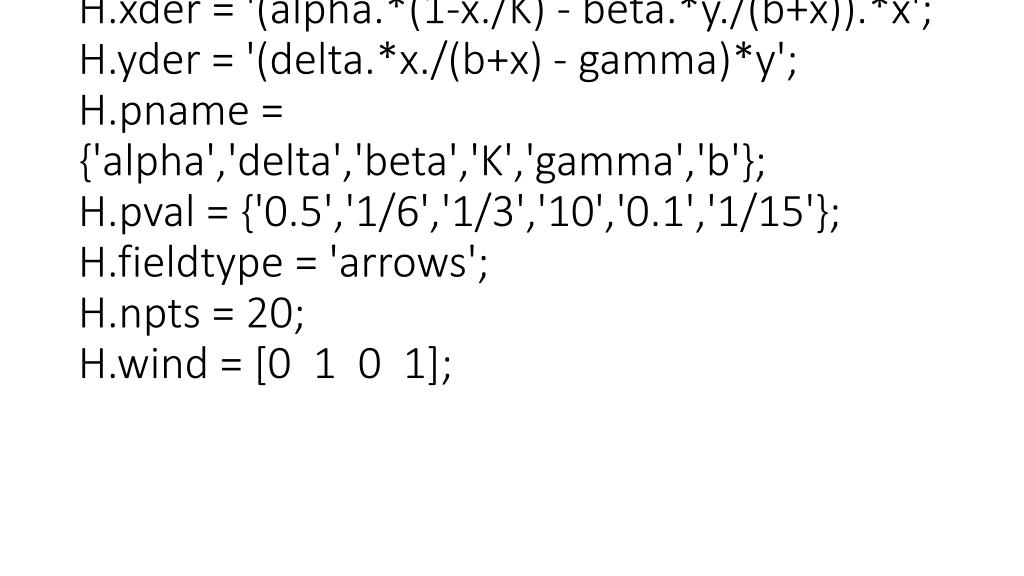
This document explores a predator-prey model characterized by the Lotka-Volterra equations, revealing the interactions of two species in a computational simulation. The model utilizes parameters including growth rates and carrying capacity to analyze stability and population dynamics. With specified initial conditions and parameter values, the simulation generates phase portraits using vector fields to illustrate the behavior of the populations over time. The model is essential for understanding ecological balance and species interaction in varying environments.
Télécharger la présentation 
Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.
F I N