SlideServe
Menu
Préférences
© SlideServe · v2026

Wearable Eye Tracker
dinah avatar
21 diapositives · 468 Views · Jul 10, 2014

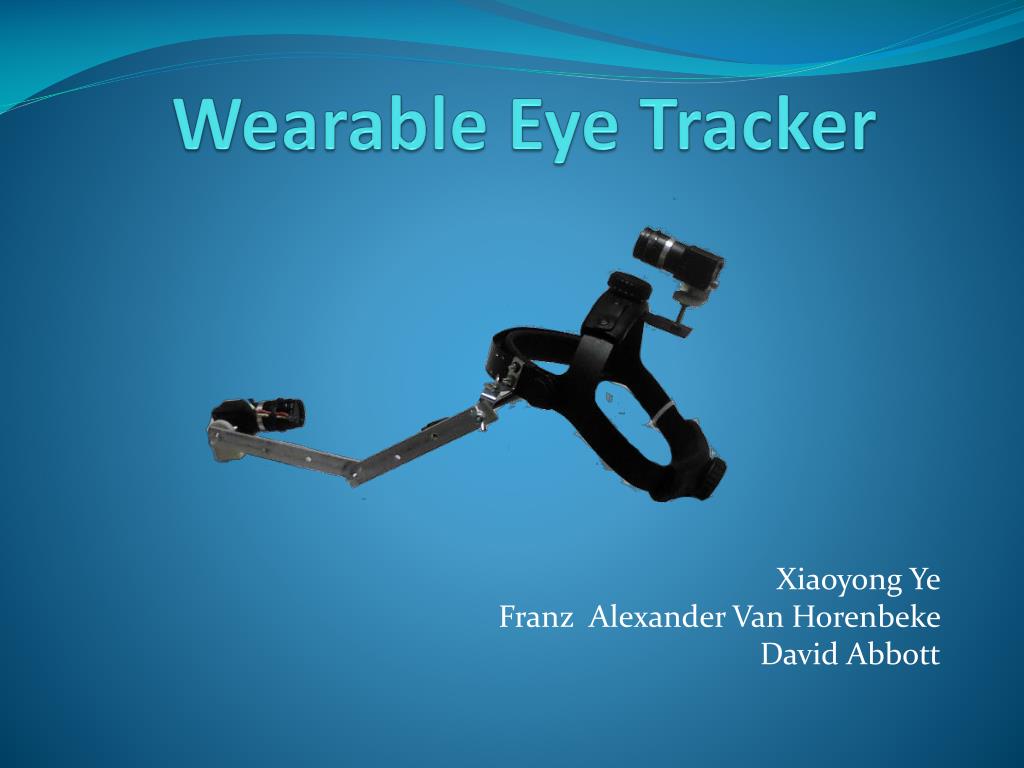
Wearable Eye Tracker. Xiaoyong Ye Franz  Alexander Van Horenbeke David Abbott. Index. Introduction Background Hardware Software System Design Algorithm Pupil Localization Ellipse Fitting Calibration Homographic Mapping Experimental Results Future Work. Introduction.
Wearable Eye Tracker - slide 1
01 / 21Wearable Eye Tracker
1 / 17

Télécharger la présentation

Wearable Eye Tracker
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Wearable Eye Tracker Xiaoyong Ye Franz  Alexander Van Horenbeke David Abbott

  2. Index • Introduction • Background • Hardware • Software • System Design • Algorithm • PupilLocalization • Ellipse Fitting • Calibration • Homographic Mapping • Experimental Results • FutureWork

  3. Introduction • A completesystemable to tracktheuser’seye and mapthepositionoftheirpupilwiththe area at whichthey are looking at inthesceneinfrontofthem

  4. Background • Wearable Eye-Tracking information • Who has done previous work • What they have used • Recent Methods used with eye tracker

  5. Objectives • Hardware • Wearable • Low-Cost • Light and Confortable • Moveableeye-camera • Software • Real-Time • Accurate

  6. Hardware • Head-MountedGear • TwoCameras: • SceneCamera • EyeCamera

  7. Hardware SceneCamera • Capturesthesceneinfrontoftheuser • Fixed to thehead EyeCamera • Capturestheeye • With 5 DOF withrespect to thehead

  8. System Design Eye Image Scene Image Yes Calibration Done? Pupil Localization No Ellipse Fitting Marker Detection Calculate Homography Ellipse Center Mapping

  9. Pupil Localization • Automatic Threshold (Modified Otsu’s Method) • Image Morphology(Dilation, Erosion) • Connected Components Analysis(Find Pupil) • Pupil Center Estimation

  10. Histogram of an Eye Image Background Pupil Graylevel Threshold

  11. Pupil Localization Threshold Erosion Connect Components Pupil Detection Dilation Fill holes

  12. Ellipse Fitting • 1. Updating the pupil Center • 2. Need 5 points for Fitting Ellipse model • 3. RANSAC to deal with noisy points

  13. EllipseFitting Edge Image • RANSAC method Starburst Algorithm Feature Points RANSAC Ellipse Fitting

  14. Calibration • Relationship between Ellipse center to Scene Image * = Homography Pupil Center Scene Position

  15. Solving for homographies X’= Hx • 8 degrees of freedom in 3 x 3 matrix H, so at least n = 8 pairs of points are sufficient to determine it • Set up a system of linear equations: Ah = 0 • where vector of unknowns h = [a,b,c,d,e,f,g,h]T • Need at least 8 eqs, but the more the better… • Solve for h. solve using least-squares

  16. calibration method 1. Look at Scene Marker and Press corresponding number on keyboard, 2. Each marker press 2 to 3 times. 3. Randomly select 8 pairs of points to calculate Homography.(Repeatly) 3. Choose the best Homography matrix.

  17. Mapping (x2, y2) (x1, y1)

  18. ExperimentalResults • Frame rate 25/second • Accurate Pupil Ellipse • Mapping error is low( 13 pixels in 640*480 image)

  19. Demo • Link • http://www.youtube.com/watch?v=lBXLpsXBGOA&context=C25ea4ADOEgsToPDskIo6A6rLXR8eySvaEf82q6h

  20. FutureWork • Hardware • Lighter cameras • Scene camera position • Software • Use corneal refletion • Try different mapping techniques

  21. Thank you!