
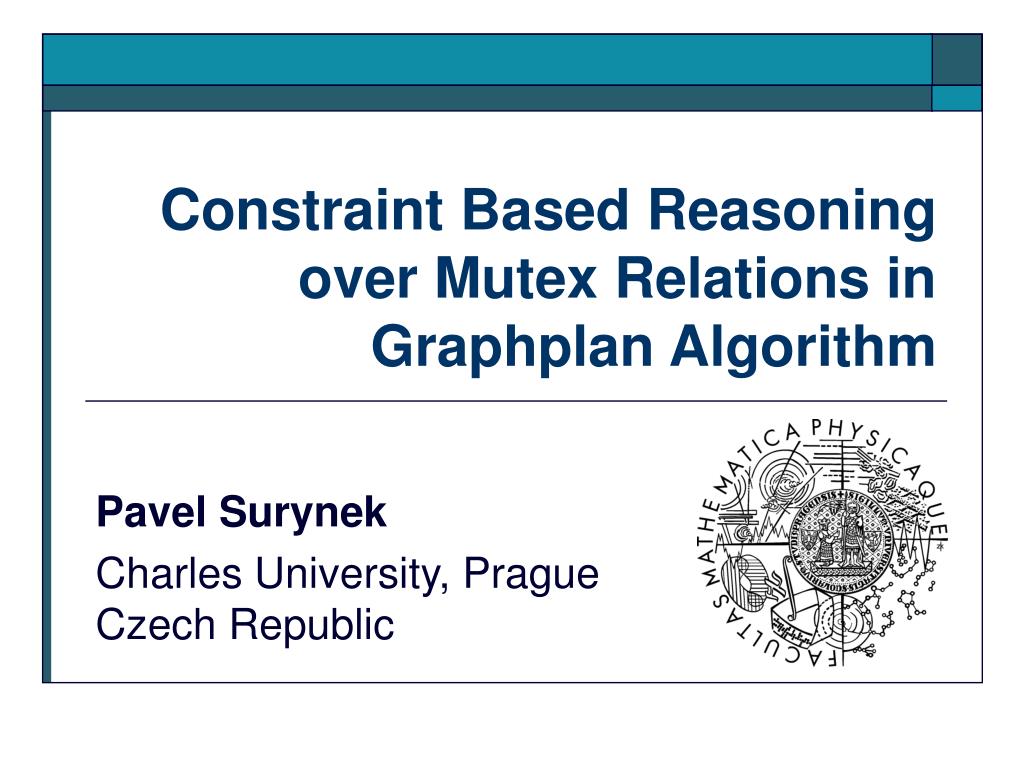
Constraint Based Reasoning over Mutex Relations in Graphplan Algorithm
This presentation by Pavel Surynek from Charles University, Prague, introduces a novel approach in AI planning through constraint-based reasoning within the Graphplan algorithm framework. It covers the fundamentals of AI planning, the reachability analysis of world states using planning graphs, and the integration of constraint mechanisms to enhance Graphplan's efficiency. Key topics include the concept of singleton arc-consistency, a revised state reachability algorithm, and the implications of mutex relationships in constructing accurate planning graphs. The talk draws on examples to illustrate state transformations and action sequences.
Télécharger la présentation 
Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.
F I N