
Distributed Planning for Large Teams: Tractability in Complex Environments

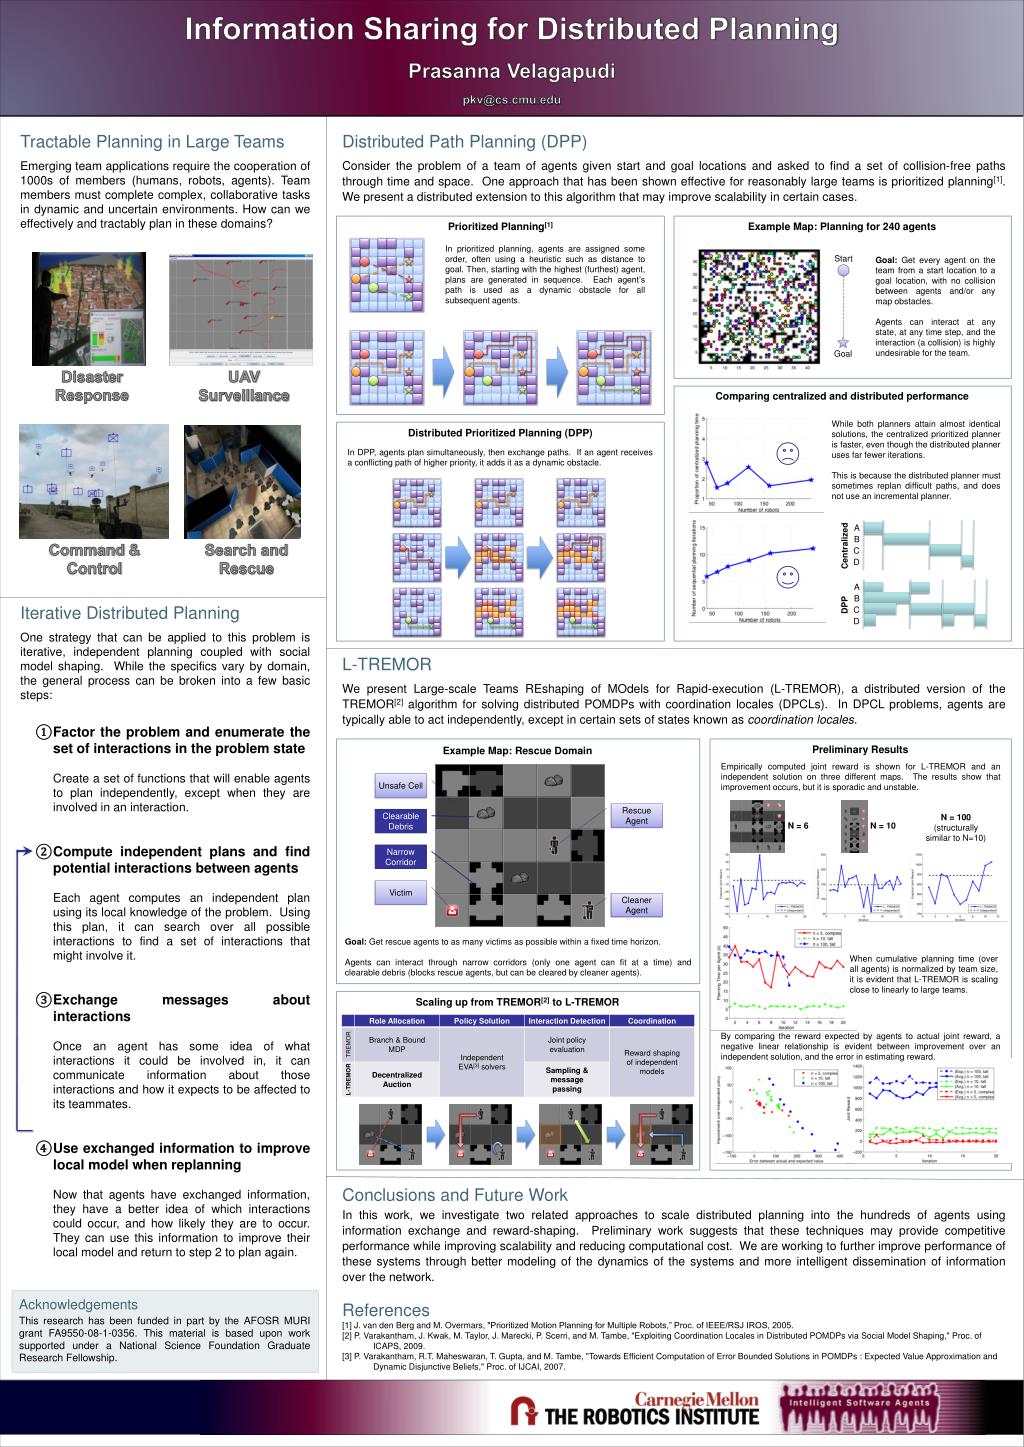
This paper investigates effective and tractable planning strategies for large teams, consisting of thousands of agents (humans, robots, or automated systems) in dynamic and uncertain environments. We explore Distributed Path Planning (DPP), a distributed algorithm that builds on prioritized planning to improve scalability and efficiency. By enabling agents to plan simultaneously and exchange path information, we reduce collisions and enhance coordination. Our results highlight the potential of L-TREMOR, a variant designed for large-scale coordination tasks, showcasing its performance in various scenarios and emphasizing the importance of information exchange for better decision-making.
Télécharger la présentation 
Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.
F I N