SlideServe
Menu
Préférences
© SlideServe · v2026

Project Overview- Strong Arm
sorcha avatar
17 diapositives · 346 Views · Aug 10, 2014

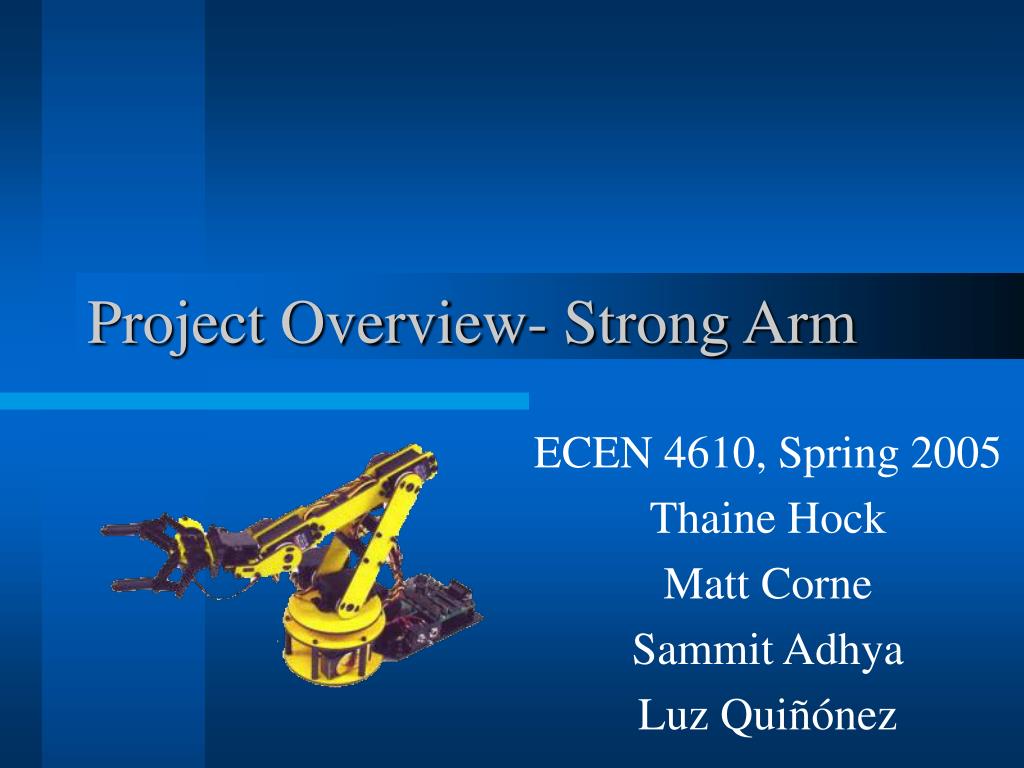
Project Overview- Strong Arm. ECEN 4610, Spring 2005 Thaine Hock Matt Corne Sammit Adhya Luz Quiñónez. Project Goals. To design and build the controlling electronics for a six-axis robotic arm that can be controlled through the use of simple finger motions
Project Overview- Strong Arm - slide 1
01 / 17Project Overview- Strong Arm
1 / 17

Télécharger la présentation

Project Overview- Strong Arm
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Project Overview- Strong Arm ECEN 4610, Spring 2005 Thaine Hock Matt Corne Sammit Adhya Luz Quiñónez

  2. Project Goals • To design and build the controlling electronics for a six-axis robotic arm that can be controlled through the use of simple finger motions • Arm will allow paraplegics to control robotic arm in three dimensions • Proof of concept of a larger scale device and training system Adhya, Corne, Hock, Quinonez

  3. Outline of Approach Finger Sensors Micro Controller Servo Controller FPGA Arm Magnetic Sensors User Interface Adhya, Corne, Hock, Quinonez

  4. Finger Sensors • Polar Coordinate Control System • Push Buttons and Limit Switches • Six directions of control • Grip and Release Adhya, Corne, Hock, Quinonez

  5. FPGA • Uses Magnetic Sensor as Inputs • Determine Initial Block Positions • Send Polar Coordinate Position to Micro Controller Using Memory-Mapped Registers Adhya, Corne, Hock, Quinonez

  6. Micro Controller • The Brain! Boahahahahaha!!! • Freescale 68HC912DG128A • 8KB SRAM • 2KB EEPROM • 128KB FLASH • SCI, SPI • ADC Onboard • 69 I/O Pins Adhya, Corne, Hock, Quinonez

  7. Servo Controller • Control Six Servos Using Serial Interface • Generates PWM signals to servos Adhya, Corne, Hock, Quinonez

  8. Arm • Lynxmotion Robotic Arm • Six degrees of freedom • Base rotation, shoulder, elbow, wrist motion, wrist rotate, and a functional gripper Adhya, Corne, Hock, Quinonez

  9. Magnetic Sensors • Place Magnets Inside Blocks • Build Magnetic Flux Detection Grid • Detect location of block using triangulation Adhya, Corne, Hock, Quinonez

  10. Division of Labor • Finger Sensor • Thaine • FPGA Implementation • Sammit • PCB and Micro controller • Thaine • Robotic Arm Algorithms • Sammit and Matt • Magnetic Sensor and Block Detection • Luz • User Interface • Matt Adhya, Corne, Hock, Quinonez

  11. Schedule Adhya, Corne, Hock, Quinonez

  12. Risks and Contingency Plan • Mapping cylindrical coordinates to servo positions may prove difficult • Magnetic sensors not sensitive enough to detect block positions • Possible use of ultra-sonic sensors Adhya, Corne, Hock, Quinonez

  13. Economic Aspects and Marketability • Training unit cost is relatively low • Practical arm cost will be very high • Moderate demand • Possibility of medical insurance covering some/most of the cost • Approx 7800 Spinal Cord Injuries each year, many of them could benefit1 1:http://www.sci-info-pages.com/facts.html Adhya, Corne, Hock, Quinonez

  14. Sustainability and Manufacturability • Parts widely available for control circuitry. • Can be used with many different arms • Effect of component tolerances are low except for a small handful • Auto-test routines in software • Complies with regulations and is safe to operate (training version) Adhya, Corne, Hock, Quinonez

  15. Pros Can be mostly lead-free No byproducts Cons Would need large battery (most likely toxic) Consumes large amounts of power Environmental Impact Adhya, Corne, Hock, Quinonez

  16. Impact on Society • Full scale device would allow some handicapped persons to be able to perform more physical tasks, qualifying them for more job opportunities Adhya, Corne, Hock, Quinonez

  17. Questions? Thanks!