SlideServe
Menu
Préférences
© SlideServe · v2026

Programmable & Autonomous Humanoid Robot ”Robovie-M”
adamdaniel avatar
7 diapositives · 598 Views · Oct 01, 2010

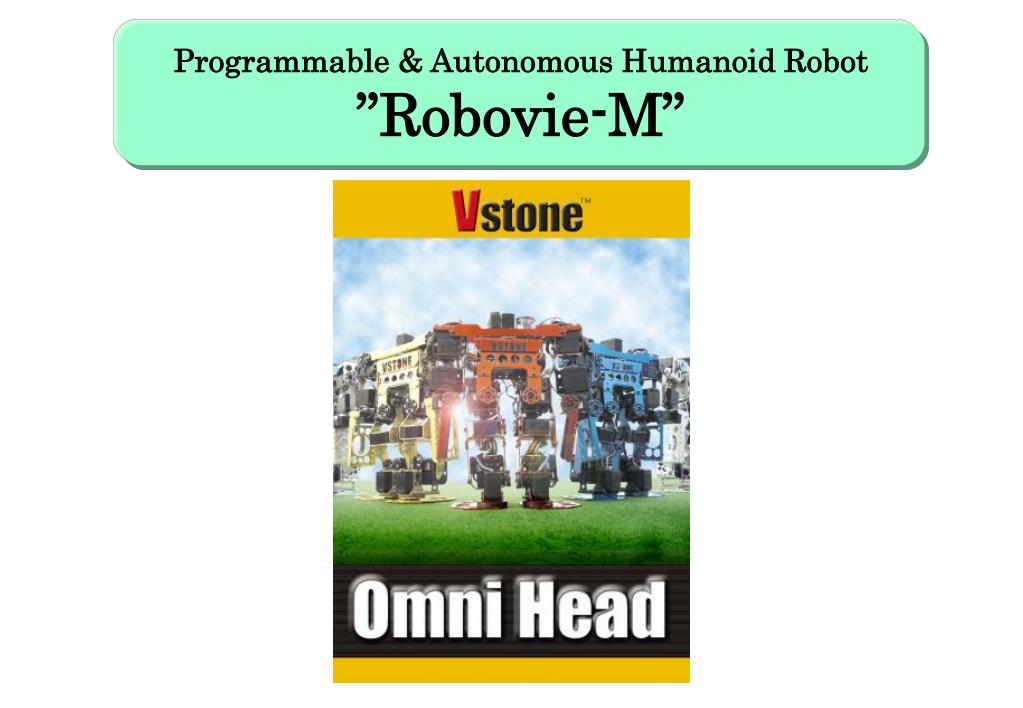
Programmable & Autonomous Humanoid Robot ”Robovie-M” Platform for Research and Development  “ Robovie-M” Overview Height:290mm/approx. 1feet Weight: approx. 1.9kg approx. 4.2 pound Feet 6 DOF x 2 Arm 4 DOF x 2 Waist 1 DOF Shoulder 1 DOF Total 22 DOF
Programmable & Autonomous Humanoid Robot ”Robovie-M” - slide 1
01 / 7Programmable & Autonomous Humanoid Robot ”Robovie-M”
1 / 17

Télécharger la présentation

Programmable & Autonomous Humanoid Robot ”Robovie-M”
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Programmable & Autonomous Humanoid Robot ”Robovie-M”

  2. Platform for Research and Development  “Robovie-M” Overview Height:290mm/approx. 1feet Weight: approx. 1.9kg approx. 4.2 poundFeet 6 DOF x 2 Arm 4 DOF x 2 Waist 1 DOF Shoulder 1 DOF Total 22 DOF CPU H8 16MHz Battery NiMH 6V 2000mAh The robot autonomously gets up after failing by monitoring the tilt sensor. Users can control with a wireless controller.

  3. Feature 1 High flexibility and unique joint arrangement realize higher mobility • OmniHead is very small and light weight, which the height is 290mm. The 22 DOF will allow for highly flexibility. In addition to the flexibility of the shoulder and waist, it has high mobility by placing an axis on bottom of robot’s feet. • The shoulder generates dynamic movements of the upper torso. • The waist takes important role when getting up. • The bottom of the robot’s feet improves the movement of taking turn. Shoulder 1 DOF Waist 1 DOF Arm 4 DOF x 2 Feet 6 DOF x 2

  4. Feature 2 Original CPU board has made the robot small The ultra-slim CPU board installed on the robot is originally developed with a unique design. Although other robots has a backpack for carrying a CPU board, our robot dose not need a backpack since the CPU board is small enough Battery The battery and CPU board are built in the robot body. We’ve carefully designed the light and small robot. CPU board

  5. Feature 3 Simple motion programming The software which ATR Intelligent Robotics and Communications Laboratories enhances users’ development of robot control program. The user can quickly make the robot motions by using the simple software interface.

  6. Example of Various Motions Getting up from falling down Throwing a ball Balancing with one leg Walking Doing a handstand Kicking