SlideServe
Menu
Préférences
© SlideServe · v2026

Formation-Based Multi-Robot Coverage
liam avatar
18 diapositives · 661 Views · Oct 01, 2010

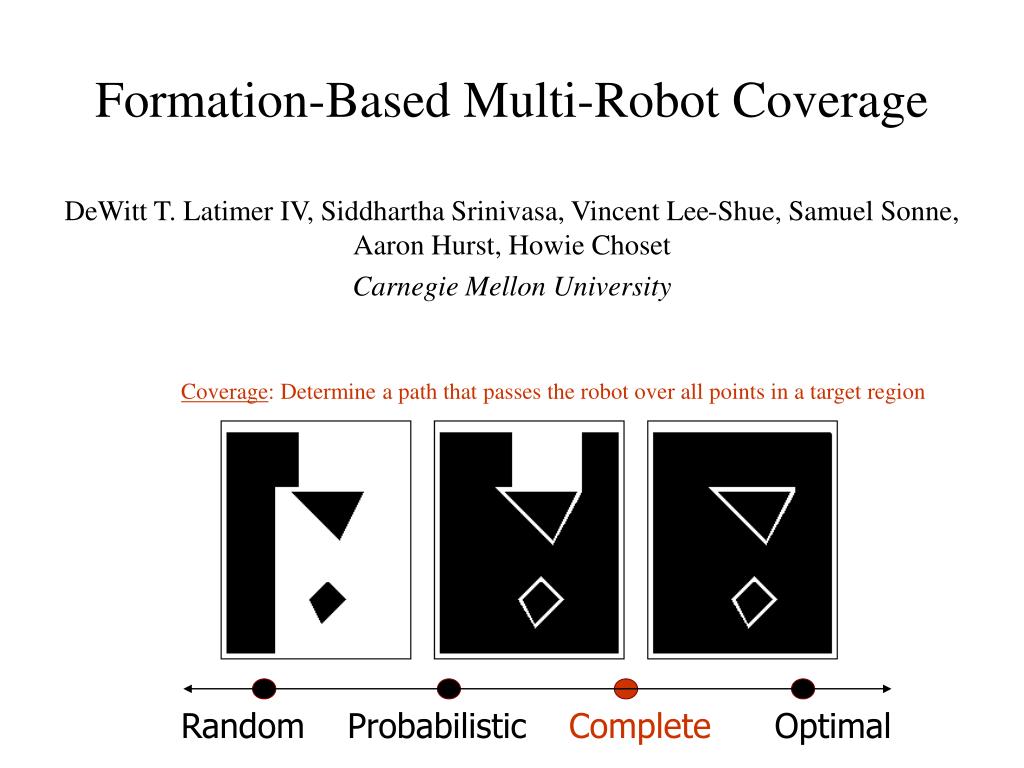
Random Probabilistic Complete Optimal Formation-Based Multi-Robot Coverage Coverage : Determine a path that passes the robot over all points in a target region DeWitt T. Latimer IV, Siddhartha Srinivasa, Vincent Lee-Shue, Samuel Sonne, Aaron Hurst, Howie Choset
Formation-Based Multi-Robot Coverage - slide 1
01 / 18Formation-Based Multi-Robot Coverage
1 / 17

Télécharger la présentation

Formation-Based Multi-Robot Coverage
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Random Probabilistic Complete Optimal Formation-Based Multi-Robot Coverage • Coverage: Determine a path that passes the robot over all points in a target region DeWitt T. Latimer IV, Siddhartha Srinivasa, Vincent Lee-Shue, Samuel Sonne, Aaron Hurst, Howie Choset Carnegie Mellon University

  2. Multi-Robot Coverage • Assumptions • Unknown space • Static obstacles • Homogenous circular robot • No marking capability • Common coordinate frame • Goals • Complete coverage of space • Coordinated, yet decentralized, among multiple robots • “Minimize” repeat coverage

  3. Final (current) Demonstration

  4. Challenges • Guaranteeing completeness • Single robot: Hert & Lumelsky, Choset & Acar, Cao • Multi-robot: Butler, Hollis, and Rizzi • Minimize repeat coverage • Planning in a multi-dimensional configuration space • Balch and Arkin, each robot acts independently • Retract methods, Yap, Choset and Burdick, Rao, Kuipers, etc. etc. • Space not known a priori • Single robot: Hert & Lumelsky, Choset & Acar, Cao • Multi-robot: Butler, Hollis, and Rizzi • Scalability

  5. Cell Decomposition and Critical Point Sensing At a critical point x,

  6. Sensor-based Complete Coverage Goal: Complete coverage of an unknown environment Cell decomposition Incremental construction Time-exposure photo of a coverage experiment

  7. Cover Interior of Cell (one corridor at a time) • Two motions • Lapping • Wall follow Wall follow Lap

  8. Characterize Critical Points

  9. Critical Point Sensing Non-lead Look for parallel vectors during forward wall following, but after a reverse wall follow, lap, and then the forward Look for anti-parallel vectors during reverse wall following Rev convex crit. pt Fwd convex crit. pt Lead Look for parallel vectors during forward wall following Look for parallel vectors during reverse wall following Rev concave crit. pt Fwd Convex crit. pt

  10. Action at Critical Points Team divides into two separate teams, each covering a new cell VIRTUAL FRONTIER (Butler) Team finishes cell and then looks for a new cell to cover

  11. Virtual Frontier As an attempt to “minimize” repeat coverage, we use the virtual frontier believing that another team will be coming from the “other” cell associated with the forward critical point

  12. Team Rejoining (work in progress) • Types of encounters • Two teams covering in opposite slice directions • Both teams finish the current corridor • Two teams covering in same slice direction • Both teams finish the current corridor • One team covering and the other traversing • Since robots only traverse through known space, the covering team stops covering and joins traversing team • Two teams encountering each other on the border of two cells (very hard case) • Combine adjacency graphs

  13. Play video Example

  14. Future: Distributed Localization and Mapping

  15. Acknowledgements • Dave Conner • Ercan Acar • Tucker Balch • Matt Mason and Mike Erdmann

  16. Why do the robots jerk back and forth during wall following?Encountering All Critical Points • Conventional back and forth motions are not sufficient • (Cao et al.’88, Hert et al.’97, Lumelsky et al.’90)

  17. NOT Occupancy Grid: Less memory, More meaningful, Minimize turns, Completeness Incremental Complete Coverage

  18. Critical Point Sensing Look for parallel vectors during forward wall following, but after a reverse wall follow, lap, and then the forward Look for anti-parallel vectors during reverse wall following Look for parallel vectors during forward wall following Look for parallel vectors during reverse wall following