SlideServe
Menu
Préférences
© SlideServe · v2026

Robosoccer Team MI20 presents …

clay avatar
50 diapositives · 678 Views · Sep 08, 2014

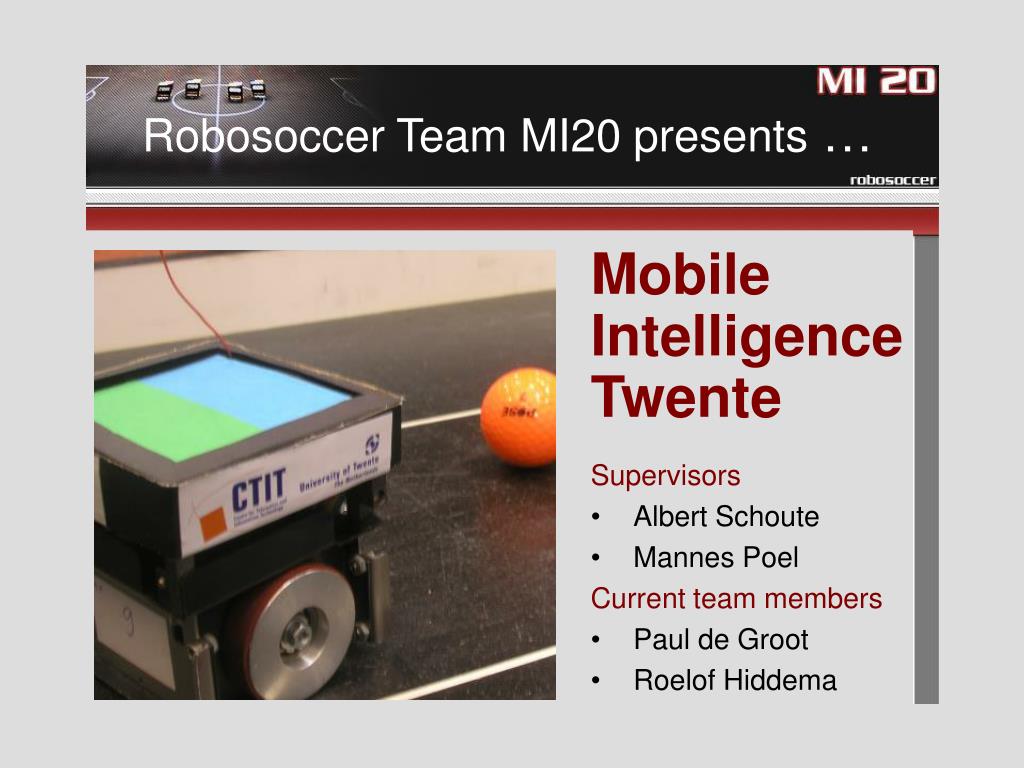
Robosoccer Team MI20 presents …. Mobile Intelligence Twente. Supervisors Albert Schoute Mannes Poel Current team members Paul de Groot Roelof Hiddema. Robot soccer as a scientific “playing field”. Interdisciplinary Hardware & Software Sensing & Control Image processing
Robosoccer Team MI20 presents … - slide 1
01 / 50Robosoccer Team MI20 presents …
1 / 17

Télécharger la présentation

Robosoccer Team MI20 presents …
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Robosoccer Team MI20 presents … Mobile Intelligence Twente • Supervisors • Albert Schoute • Mannes Poel • Current team members • Paul de Groot • Roelof Hiddema

  2. Robot soccer as a scientific “playing field” Interdisciplinary • Hardware & Software • Sensing & Control • Image processing • Motion planning • Multi-agent collaboration • Communication • Artificial intelligence International • Championships(FIRA, Robocup) • Congresses

  3. Mission Impossible ?

  4. Robocup Humanoid Small size Middle size Four-Legged Rescue Junior Simulation @Home FIRA HuroSot KheperaSot MiroSot UT team NaroSot QuadroSot RoboSot SimuroSot International leagues

  5. Robocup Humanoid 2 vs. 2 (Osaka 2005)

  6. FIRA Humanoid (Vienna 2003)

  7. Robocup Middle League

  8. Robocup Small League

  9. FIRA Mirosot (11 vs. 11)

  10. FIRA Mirosot competitie • Games between teams of 5, 7 or 11 robots • Camera’s above the field observe the playing • Computers control the robots wirelessly

  11. MiroSot robots • Maximal dimensions:7.5 x 7.5 x 7.5 cm • Two-wheeled differential drive robots • Board-computer controls wheel velocities

  12. Impression of EC 2005 @ UT

  13. Twente’s robosoccer team • Started in 2002: Missing Impossible Mission Impossible Mobile Intelligence

  14. Generations of students 4th teamVienna 2006 1st teamLjubljana 2003

  15. Generations of robots

  16. Home base

  17. Computer control

  18. Localization • Robots have color patches on top • Design is free, except for obligatory team color • Design choice:identical or different patterns per robot? • Identical  makes recognition simpler, but robots must be tracked

  19. Vision

  20. Camera image

  21. Color segmentation

  22. Color separation

  23. Region clustering

  24. Camera calibration • Lens distortion

  25. Image correction • Remap feature points only

  26. Correction of projective mapping • Automatic field calibration by 4 known markers

  27. Correct for parallax

  28. Tracking

  29. y (x,y) )θ x State estimation

  30. Result on the screen

  31. Motion Control • Robots have local PID velocity controllers • Motion commands  wheel speeds (vr, vl) cq. lin. & ang. velocities (v, ) • Kinematic robot model • Higher speeds: account for dynamics!

  32. Motion Planning Driving fast to play the ball while avoiding obstacles …

  33. Strategy ? The team’s magic

  34. System design ? The team’s pain

  35. (Re)designing for the winning team Initial MI20 multi-agent system architecture:

  36. 1st team motion controller Solve the parking problem: move to “pose” (x, y, )

  37. … while avoiding obstacles Local method: Vector Field Histogram Corresponding Histogram

  38. Trying out in de simulator

  39. Shoot and score!

  40. Shoot and miss!

  41. 2 2 1 1 2 1 1 2 Improvements Avoid tracking errors by collision analysis Real Prediction

  42. pred1 pred2 γ last2 last1 Collision prediction

  43. pred1 pred2 corr2 corr1 last2 last1 Collision state correction

  44. n VA VB A P B Collision response model

  45. VA ωA ωB A VB P B Collision response (cont.)

  46. Improving strategy Choosing optimal offensive / defensive positions

  47. Improved system structure • Complete software revision • Reduced thread concurrency • Simplified interprocess communication • Current O.S.Linux Fedora Core 4

  48. Coming soon …

  49. TU Vienna Parade

  50. Questions?