
Enhancing Mobile Robot Learning through Human Knowledge Integration and Adaptive Navigation
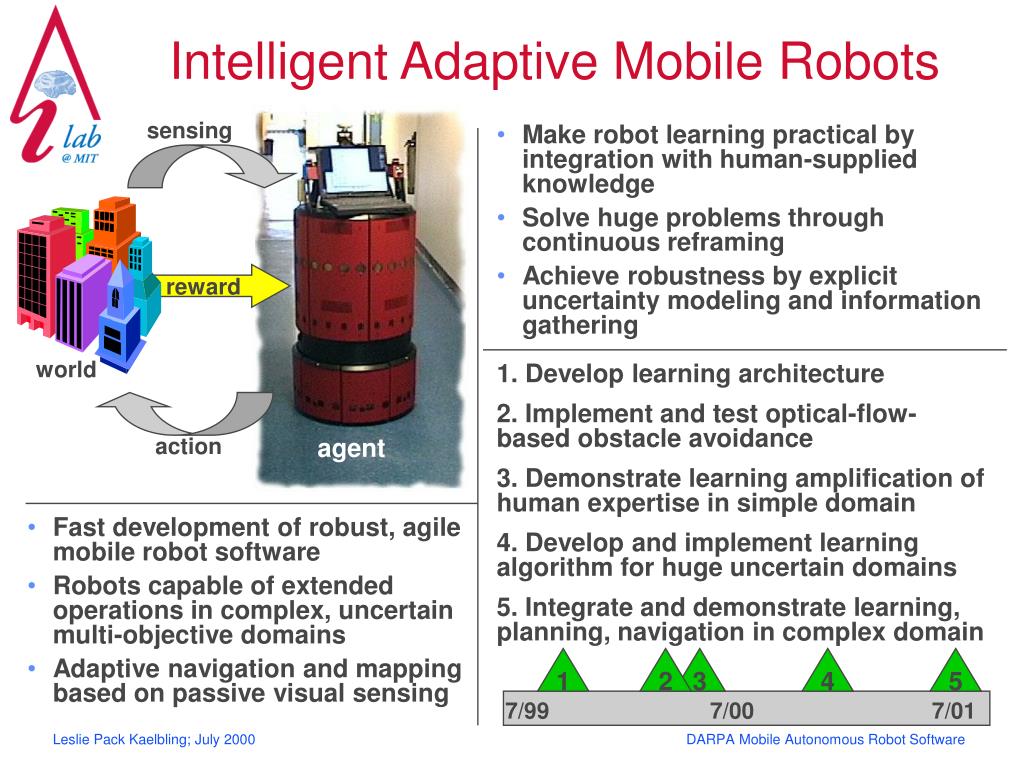
This project focuses on developing intelligent adaptive mobile robots that utilize human-supplied knowledge to enhance their learning and decision-making capabilities. By employing continuous reframing to tackle complex problems, these robots will achieve robustness through explicit uncertainty modeling and proactive information gathering. Key components include implementing an optical-flow-based obstacle avoidance system, amplifying human expertise, and integrating learning, planning, and navigation in multi-objective, uncertain environments. The overarching goal is to create agile robots capable of extended operations in complex domains.
Télécharger la présentation 
Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.
F I N