SlideServe
Menu
Préférences
© SlideServe · v2026

Dynamic Response

tab avatar
30 diapositives · 482 Views · Oct 15, 2014

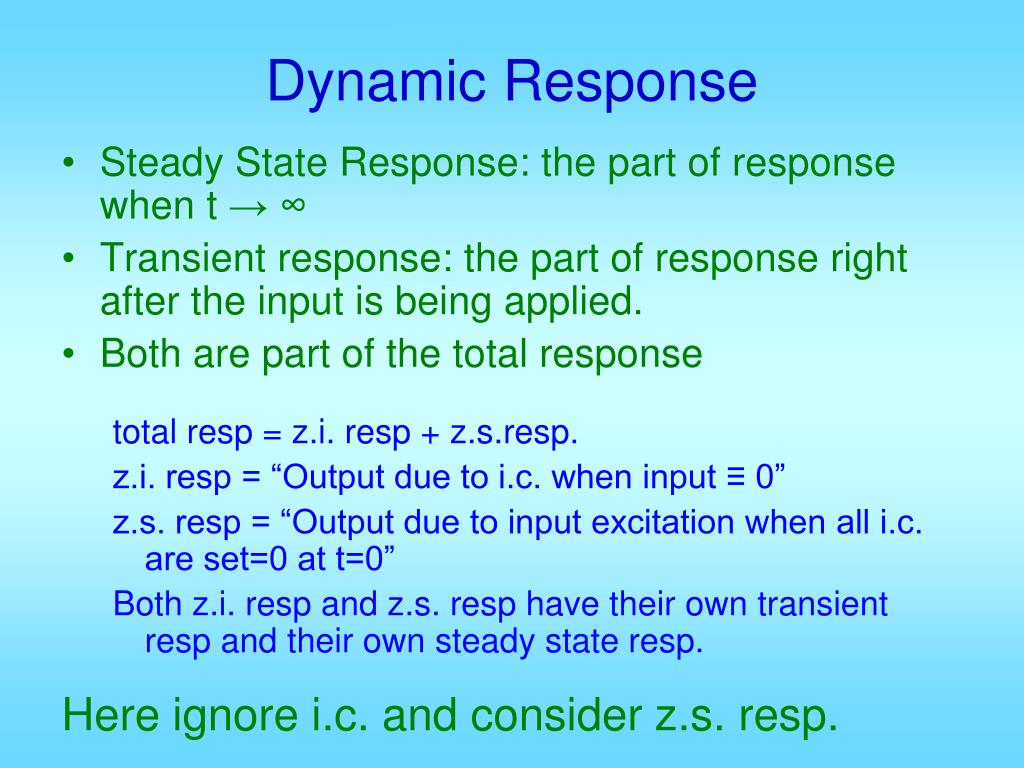
Dynamic Response. Steady State Response: the part of response when t → ∞ Transient response: the part of response right after the input is being applied. Both are part of the total response total resp = z.i. resp + z.s.resp. z.i. resp = “Output due to i.c. when input ≡ 0”
Dynamic Response - slide 1
01 / 30Dynamic Response
1 / 17

Télécharger la présentation

Dynamic Response
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Dynamic Response • Steady State Response: the part of response when t → ∞ • Transient response: the part of response right after the input is being applied. • Both are part of the total response total resp = z.i. resp + z.s.resp. z.i. resp = “Output due to i.c. when input ≡ 0” z.s. resp = “Output due to input excitation when all i.c. are set=0 at t=0” Both z.i. resp and z.s. resp have their own transient resp and their own steady state resp. Here ignore i.c. and consider z.s. resp.

  2. us(t) 1 0 Typical test signal • Unit step signal: • Unit impulse:δ(t) δ(t) t

  3. Unit ramp: • Unit acc. signal: r(t) t a(t) 0.5 0 1 t

  4. Exponential signal: • sinusoidal: 1 0 t

  5. 1 s 1 s y(s)=H(s) u(s)= H(s) • Unit step response: In Matlab: step • Unit impulse resp: Matlab: impulse y(s)=H(s) u(s)=1 H(s)

  6. Defined based on unit step response • Defined for closed-loop system • Steady-state value yss • Steady-state error ess • Settling time ts • = time when y(t) last enters a tolerance band Time domain response specifications

  7. If yss = 1 tp

  8. By final value theorem In MATLAB: num = [ .. .. .. .. ]; den=[……]; b0 = num(length(num)), or num(end) a0 = den(length(den)), or den(end) yss=b0/a0

  9. If numerical values of y and t available, from [y, t]=step(num, den); abs(y – yss) < tol means inside band abs(y – yss) ≥ tol not inside e.g. t_out = t(abs(y – yss) >= tol) contains all those time points when y is not inside the band. Therefore, the last value in t_out will be the settling time. ts=t_out(end)

  10. Peak time tp = time when y(t) reaches its maximum value. Peak value ymax =y(tp) Hence: ymax = max(y); tp = t(y = ymax); Overshoot: OS = ymax - yss Percentage overshoot:

  11. If t50 = t(y >= 0.5*yss), this contains all time points when y(t) is ≥ 50% of yss so the first such point is td. td=t50(1); Similarly, t10 = t(y >= 0.1*yss) & t90 = t(y >= 0.9*yss) can be used to find tr. tr=t90(1)-t10(1)

  12. 90%yss 10%yss tr≈0.45 ts ts tp≈0.9sec td≈0.35

  13. ±5% ts=0.45 yss=1 ess=0 O.S.=0 Mp=0 tp=∞ td≈0.2 tr≈0.35

  14. tp=0.35 O.S.=0.4 Mp=40% yss=1 ess=0 ts≈0.92 td≈0.2 tr≈0.1

  15. Transient Response • First order system transient response • Step response specs and relationship to pole location • Second order system transient response • Step response specs and relationship to pole location • Effects of additional poles and zeros

  16. Prototype first order system E 1 τs Y(s) U(s) + -

  17. First order system step resp Normalized time t/t

  18. Prototype first order system • No overshoot, tp=inf, Mp = 0 • Yss=1, ess=0 • Settling time ts = [-ln(tol)]/p • Delay time td = [-ln(0.5)]/p • Rise time tr = [ln(0.9) – ln(0.1)]/p • All times proportional to 1/p= t • Larger p means faster response

  19. The error signal: e(t) = 1-y(t)=e-ptus(t) Normalized time t/t

  20. In every τseconds, the error is reduced by 63.2%

  21. General First-order system We know how this responds to input Step response starts at y(0+)=k, final value kz/p 1/p = t is still time constant; in every t, y(t) moves 63.2% closer to final value

  22. Step response by MATLAB: >> p = . . >> n = [ b1 b0 ] >> d = [ 1 p ] >> step ( n , d ) Other MATLAB commands to explore: plot, hold, axis, xlabel, ylabel, title, text, gtext, semilogx, semilogy, loglog, subplot

  23. Unit ramp response:

  24. Note: In step response, the steady-state tracking error = zero.

  25. Unit impulse response: