SlideServe
Menu
Préférences
© SlideServe · v2026

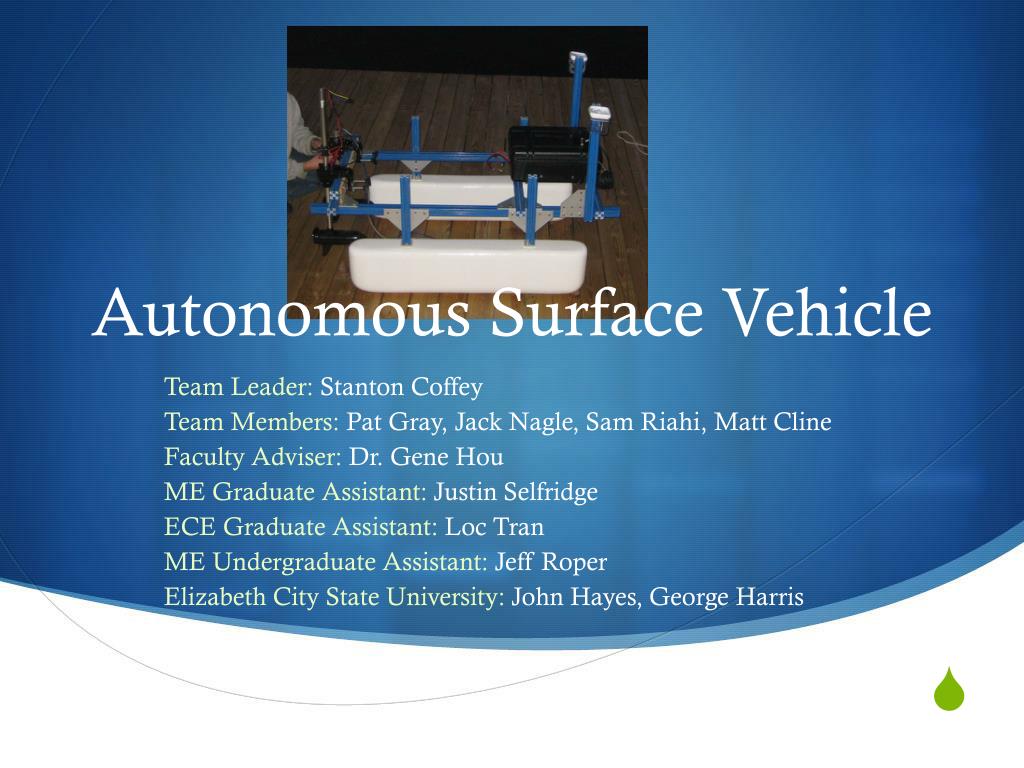
Autonomous Surface Vehicle

vita avatar
9 diapositives · 358 Views · Oct 06, 2014

Autonomous Surface Vehicle. Team Leader: Stanton Coffey Team Members: Pat Gray, Jack Nagle, Sam Riahi , Matt Cline Faculty Adviser: Dr. Gene Hou ME Graduate Assistant: Justin Selfridge ECE Graduate Assistant: Loc Tran ME Undergraduate Assistant: Jeff Roper
Autonomous Surface Vehicle - slide 1
01 / 9Autonomous Surface Vehicle
1 / 17

Télécharger la présentation

Autonomous Surface Vehicle
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. Autonomous Surface Vehicle Team Leader: Stanton Coffey Team Members: Pat Gray, Jack Nagle, Sam Riahi, Matt Cline Faculty Adviser: Dr. Gene Hou ME Graduate Assistant: Justin Selfridge ECE Graduate Assistant: LocTran ME Undergraduate Assistant: Jeff Roper Elizabeth City State University: John Hayes, George Harris

  2. Purpose • To enter into an international competition against other universities. We must build an autonomous unmanned boat to navigate a course and complete sub-mission tasks. Within certain guidelines • Above water (not sub-marine) • Must weigh < 140 lbs • Within dimensions 6’ x 3’ x 3’

  3. Main Mission Tasks&Sub-mission Tasks • Main Mission Tasks • Strength Test • Speed Test • Maneuvering Test • Sub-Mission Tasks • Amphibious landing • Find the fire and extinguish it • Find and report the hot target • Turn off the waterfall

  4. Previous Work (last semester) • Boat frame construction • Modular Design, Movable Components • Motors Design • 2 Motors (optimal thrust, easy maneuvering) • Pontoons • 2 Pontoons for maximum stability • Electrical Box • Battery choice, box components • Camera Mounting

  5. Current Work Water Testing

  6. Current Work(Cont.) Water Testing

  7. Current Problems • Electrical Box • Not water proof, incorrectly rated fuses, poor wiring (wires slip off) • Frame / Motors • Frame poorly measured (needs to be squared) • Motors not securely locked (are able to rotate while running) • Pontoons • Current pontoons give barely enough buoyancy and there is still weight to be added.

  8. To Do List • Lock Motors in place • Fix Wiring • Make a cart to transport the boat and to lower the boat into the water (required by competition) • Water proof electrical box • Test GPS and Compass • Test Kinect Cameras

  9. Questions?