SlideServe
Menu
Préférences
© SlideServe · v2026

This Week

allayna avatar
21 diapositives · 440 Views · Aug 11, 2014

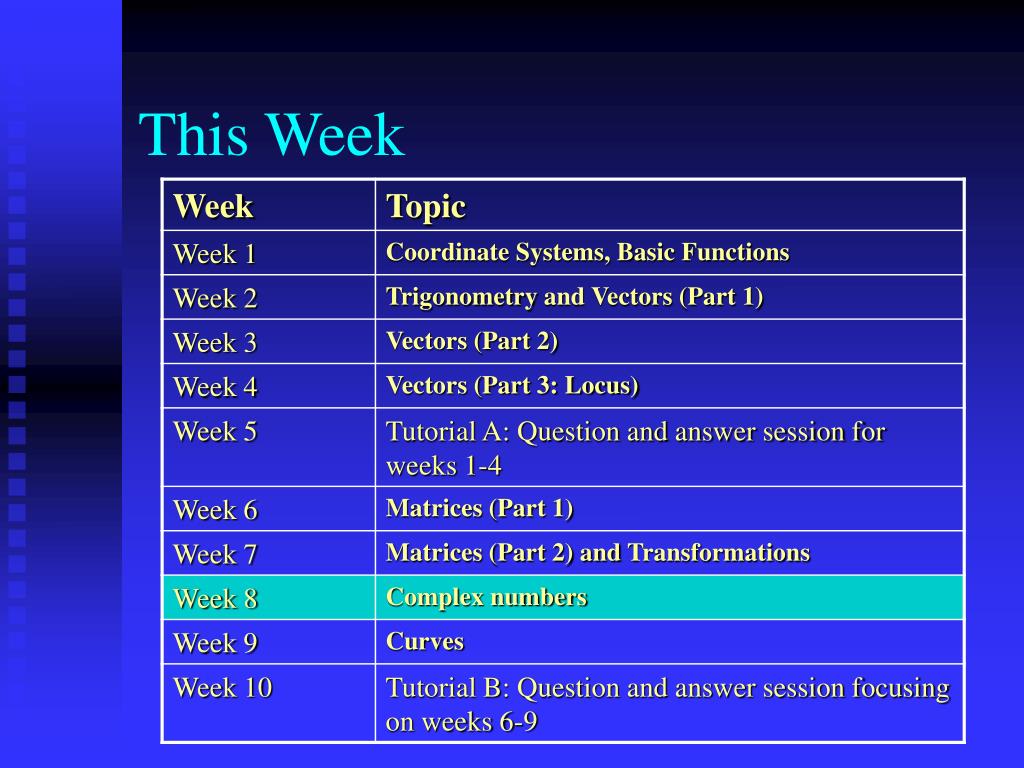
This Week. Short Course in: Mathematics and Analytic Geometry. Week 8 Complex Numbers. Unreal Quadratic Roots. The roots of quadratic equations: can be found using the quadratic formula : However, if (b 2 < 4ac) then the roots are not real. Unreal Quadratic Roots.
This Week - slide 1
01 / 21This Week
1 / 17

Télécharger la présentation

This Week
Une image / un lien ci-dessous est fourni (tel quel) pour télécharger la présentation

Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.

F I N

Plus de contenu associé

Transcription de la présentation
  1. This Week

  2. Short Course in: Mathematics and Analytic Geometry Week 8 Complex Numbers

  3. Unreal Quadratic Roots • The roots of quadratic equations: can be found using the quadratic formula: However, if (b2 < 4ac) then the roots are not real.

  4. Unreal Quadratic Roots • For example, consider roots for the quadratic equation: • The square root of (-1) is undefined in the real number set.

  5. Imaginary Numbers • Terms involving the square root of (-1) form a new numbers, called Imaginary numbers: • The roots for:

  6. Complex Numbers • Quite often imaginary terms appear in sums with real terms; for example: • A complex number is any number that can be expressed in this form: • This implies that real numbers are a subset of the complex numbers.

  7. The Imaginary Powers • The properties of i is as follows: • These powers have a cycle length of 4:

  8. The Complex Plane • Given the distinction between imaginary and real numbers, complex numbers can represent points in a plane:

  9. Complex Numbers in Polar Form • Complex numbers can also be expressed in terms of radius and angle:

  10. Euler’s Formula • Given the power expansions of sin x, cos x and ex: • If x is imaginary:

  11. Complex Number Notations • Just as with vectors, complex numbers can be represented by a single letter (usually z): • Other notations:

  12. Conjugate Pairs • Given a complex number (x + yi), its conjugate pair is (x - yi) and has the following properties:

  13. Euler Rotations • Euler rotations are given by translating the centre of rotation of an object to the origin and applying rotation matrices: • Sometimes called: yaw,roll and pitch.

  14. Gimbals Lock • When rotation matrices are applied in a fixed order (usually pitch, roll and yaw) their operations represent a system of rotation gimbals: • Gimbals lock occurs when any two of these frames coincide on the same plane.

  15. Gimbals Lock • For example, assume we apply rotations in pitch, roll and yaw order, all rotation angles are initially zero and we choose to roll π/2 radians: • Any pitch change is independent of roll and yaw: • However, yaw depends on roll: the result is an anticlockwise pitch rotation, we have lost yaw.

  16. The Quaternion* • A Quaternion can be defined as an extended complex number having the form: • The imaginary parts are as follows:

  17. Quaternion Inverse • Given a quaternion q, the inverse can be found as follows:

  18. Quaternion Rotation • Assume we have a unit vector u and a position vector v and we want to rotate the point described by vector v clockwise about an axis described by u:

  19. Quaternion Rotation • We can define a quaternion q such that: • And θ defines the intended angle of rotation.

  20. Quaternion Rotation • Given quaternion q, a clockwise rotation of θ radian, of a position vector v about the unit vector u, can be defined by the following mapping:

  21. Next Week • SLERP • Curves, Splines and Patches