
Implementing Robot Navigation in Room Sequence Using IndiGolog

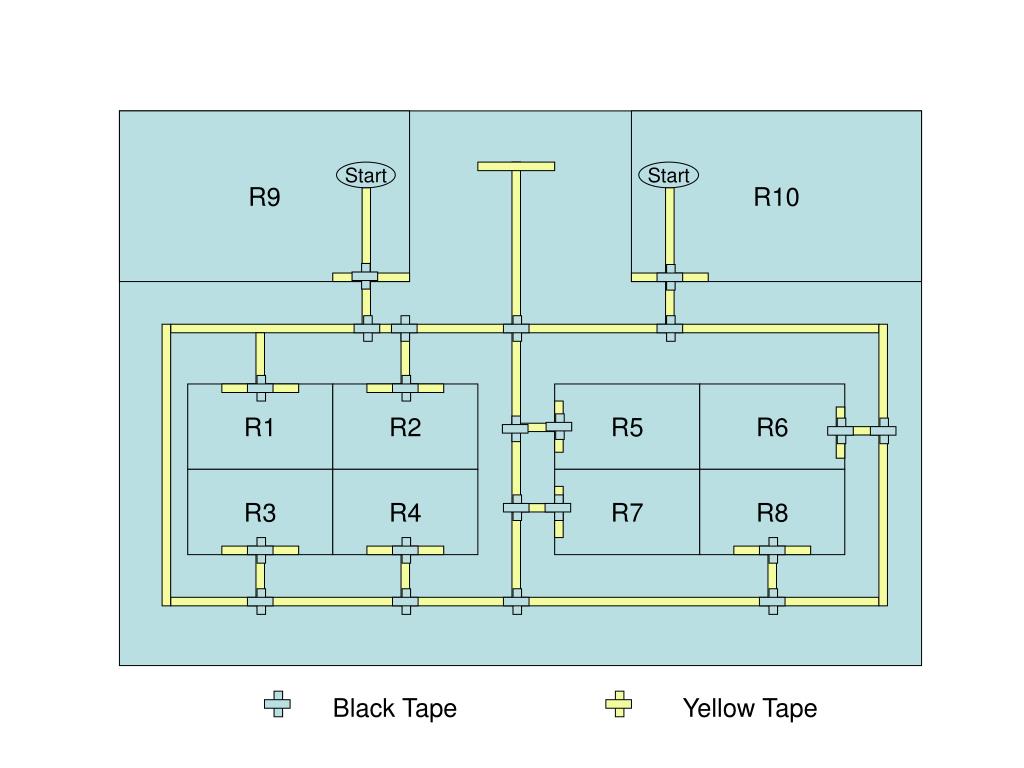
This project involves programming a robot to navigate through a series of rooms numbered 1 to 10 based on a given sequence of room numbers. The robot starts from one of two defined 'Start' nodes and must visit each room in the specified sequence before returning to the starting position. We'll provide a situation calculus theory to outline the domain and develop an IndiGolog program to accomplish this task. The program will be implemented in Legolog, incorporating capabilities for dynamically adding or deleting destinations during execution.
Télécharger la présentation 
Politique de téléchargement : le contenu du site vous est fourni TEL QUEL pour votre information et votre usage personnel ; il ne peut être vendu, concédé sous licence ni partagé sur d’autres sites sans l’accord de son auteur.Le contenu vous est fourni TEL QUEL, pour votre information et votre usage personnel uniquement. Téléchargez la présentation en cliquant sur ce lien. Lors du téléchargement, si vous ne parvenez pas à télécharger une présentation, l’éditeur a peut-être supprimé le fichier de son serveur.Pendant le téléchargement, si vous ne parvenez pas à obtenir une présentation, le fichier a peut-être été supprimé par l’éditeur.
F I N